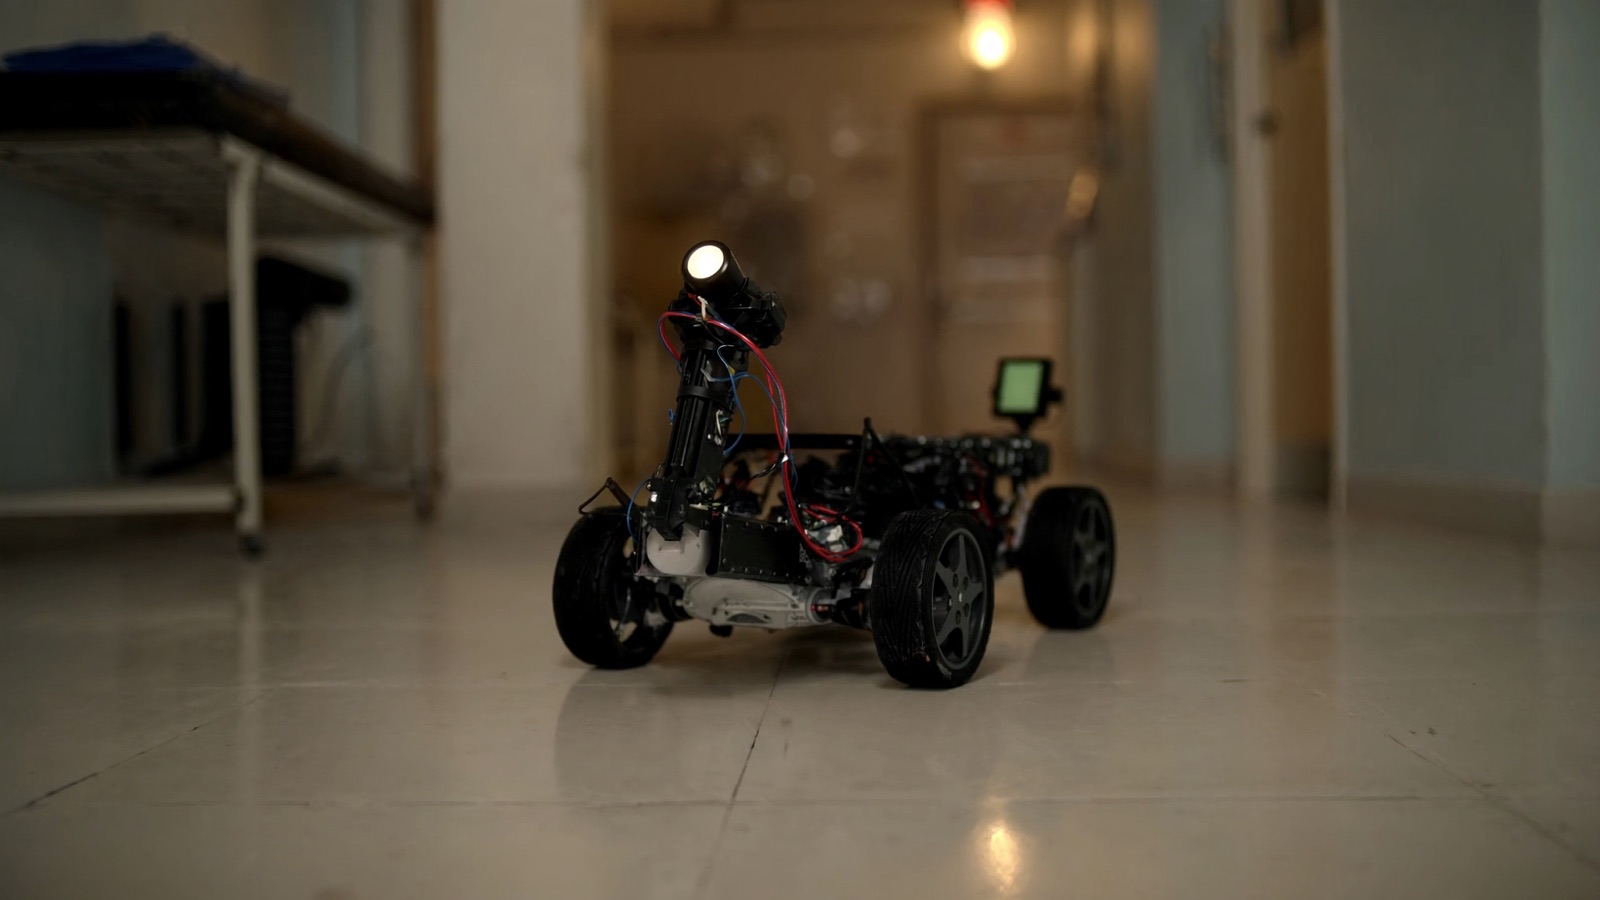
The Lumos Ego is a Research robot developed by Lumos Robotics (China).
RoboScore
Weak evidence
No confirmed deployment on record — this score reflects the rest of the record, not verified adoption.
3 of 9 signals present
Recomputed nightly from public data. Missing data is skipped, never zero-filled — and rankings are never for sale.
Weighted factors
average of the 3 scored · blanks don't count
Ranked #32 of 68 in the Research standing.
See the standingWhere it has stood44 days · best #31 · worst #60
3 days carry something the board can name:
- 19 Aug Its maker's news lifted the score 3.74 — the board noticed.
- 7 Sept RoboScore rose 7.44 — its evidence changed.
- 20 Sept Its maker's news lifted the score 1.13 — the board noticed.
One reading per day since 10 Aug, when the current ordering began. The rank above is the reading for 23 Sept, taken against 68 robots — the standing itself is live, so a robot added since then counts there and not here yet.
Will it fit your job?
Tell us the job in plain words — we'll show how this robot measures up, line by line.
Tell us what your job needs — payload, budget, region, must-have certifications — and we'll show how Lumos Ego measures up, requirement by requirement. The RoboScore (trust) above is shown for every buyer, regardless.
Overview
The Lumos Ego is a head-mounted egocentric multimodal data-collection device designed for capturing training data for manipulation learning. It integrates a wide-angle fisheye camera, high-precision SLAM, hand-joint tracking, and multimodal synchronization. It tracks more than 42 hand-joint keypoints across both hands and provides microsecond-level hardware timestamp alignment across RGB, ToF, SLAM pose, and IMU streams. The device weighs only 235g and supports a wide 20° to 180° viewing adjustment range. It natively supports Ubuntu 20.04 and ROS/ROS2. The STD version includes ToF depth sensing while the Lite version does not.
At a glance
- Built for research development
- Used across research academic
- Programmed through python and ROS
- Public API for integration
- Compatible with ROS
Buyer decision signals
Viability
Price
Published figures are build cost or program budget, not a purchase price
Availability
Specifications
Category: Research- Payload
- 3 kg
- Weight
- 0.24 kg
- Battery
- 2 h
- Price
- Research platform
- Status
- active
Published figures are build cost or program budget, not a purchase price
Company profile
- Confirmed funding
- US$293.8M· 2 rounds
- Founded
- 2024
Detailed specifications
What it is built for6
- Applications
- research
- Sub Category
- data collection device
- Industries Served
- research academic
- Target Industries
- research academic
- Primary Applications
- research development
- Deployment Environment
- indoor
Movement & precision2
- Dof
- 6
- Arm Dof
- 7
Controls & integration9
- Head Cameras
- 5
- Sensor Suite
- fisheye camera,slam cameras,tof camera,imu
- Api Available
- true
- Sdk Languages
- Python,C++,ROS2
- Ros Compatible
- true
- Network Protocols
- ethernet
- Software Platform
- Ubuntu 20.04 & 22.04
- Compatible Grippers
- Optional gripper
- Programming Interface
- code python,code ros
Buying & support6
- Price Tier
- 40-80K
- Model Variants
- STD,Lite
- Price On Request
- true
- Country Of Origin
- CN
- Is Research Grade
- true
- Availability Status
- backorder
Other details37
- Imu
- 9-axis @ 500Hz
- Imu Type
- 6-axis ICM42688
- Imu Count
- 1
- Time Sync
- microsecond-level hardware timestamp alignment
- Os Support
- Ubuntu 20.04
- Rgb Camera
- 1280x1280 @ 60fps, FOV >180°
- Max Power W
- 4
- Ros Support
- ros2 community
- Slam Cameras
- 4x 640x480 @ 30fps, HFOV 130°
- Headband Type
- high-elastic knitted
- Power Voltage
- 5V
- Arm Payload Kg
- 3
- Data Interface
- USB 3.2 Type-C 10Gbps
- Hand Keypoints
- 42
- Tof Camera Fov
- D78° H64° V50°
- Tof Camera Fps
- 30
- Slam Camera Fov
- HFOV 130°
- Slam Camera Fps
- 30
- Tof Depth Error
- <1.5% within 2m
- Hand Pose Output
- 4x4 Joint Transformation Matrix, rpy + quaternion supported
- Imu Frequency Hz
- 500
- Field Of View Deg
- 200
- Slam Camera Count
- 4
- Confidence Scoring
- per-frame algorithm confidence values
- Fisheye Camera Fov
- DFOV=200°, HFOV=172.52°, VFOV=172.52°
- Fisheye Camera Fps
- 60
- Housing Max Temp C
- 40
- Hand Joints Tracked
- 66
- Programming Methods
- hand coded
- Hand Joint Keypoints
- 42
- Tof Camera Resolution
- 320x240
- World Frame Alignment
- built-in SLAM auto-aligns hand and device trajectories in a single coordinate system
- Slam Camera Resolution
- 640x480
- Hand Keypoints Per Hand
- 21
- Power Consumption Peak W
- 4
- Fisheye Camera Resolution
- 1280x1280
- Tethered Operation Available
- true
Who runs it· deployment evidence
No deployment evidence on file
A deployment is recorded when a public source names the customer, or the maker confirms it. Nothing here counts against this robot.
7 other robots in this category have one.
Add a deployment →Compare with peers
Lumos Robotics in the news
the maker8 events · last 12 months
Lumos Robotics Launches NexCore to Cut Robotic Skill Development from Weeks to Days
Lumos Robotics in the news
the maker8 events · last 12 months
News about Lumos Robotics, the maker — not about this robot specifically, except rows marked this robot. Collected and classified independently across 10 outlets, so a maker cannot add to it. It never changes this robot's RoboScore — the evidence half of the RoboIndex — and it can move it up a board by at most 15 points. See all Lumos Robotics news
Frequently asked questions
- Who makes the Lumos Ego?
- The Lumos Ego is developed by Lumos Robotics, based in China.
- What type of robot is the Lumos Ego?
- The Lumos Ego is a Research robot made by Lumos Robotics.
- How much does the Lumos Ego cost?
- Pricing for the Lumos Ego is not publicly listed — contact Lumos Robotics for a quote.
Reviews for Lumos Ego
Loading reviews…